
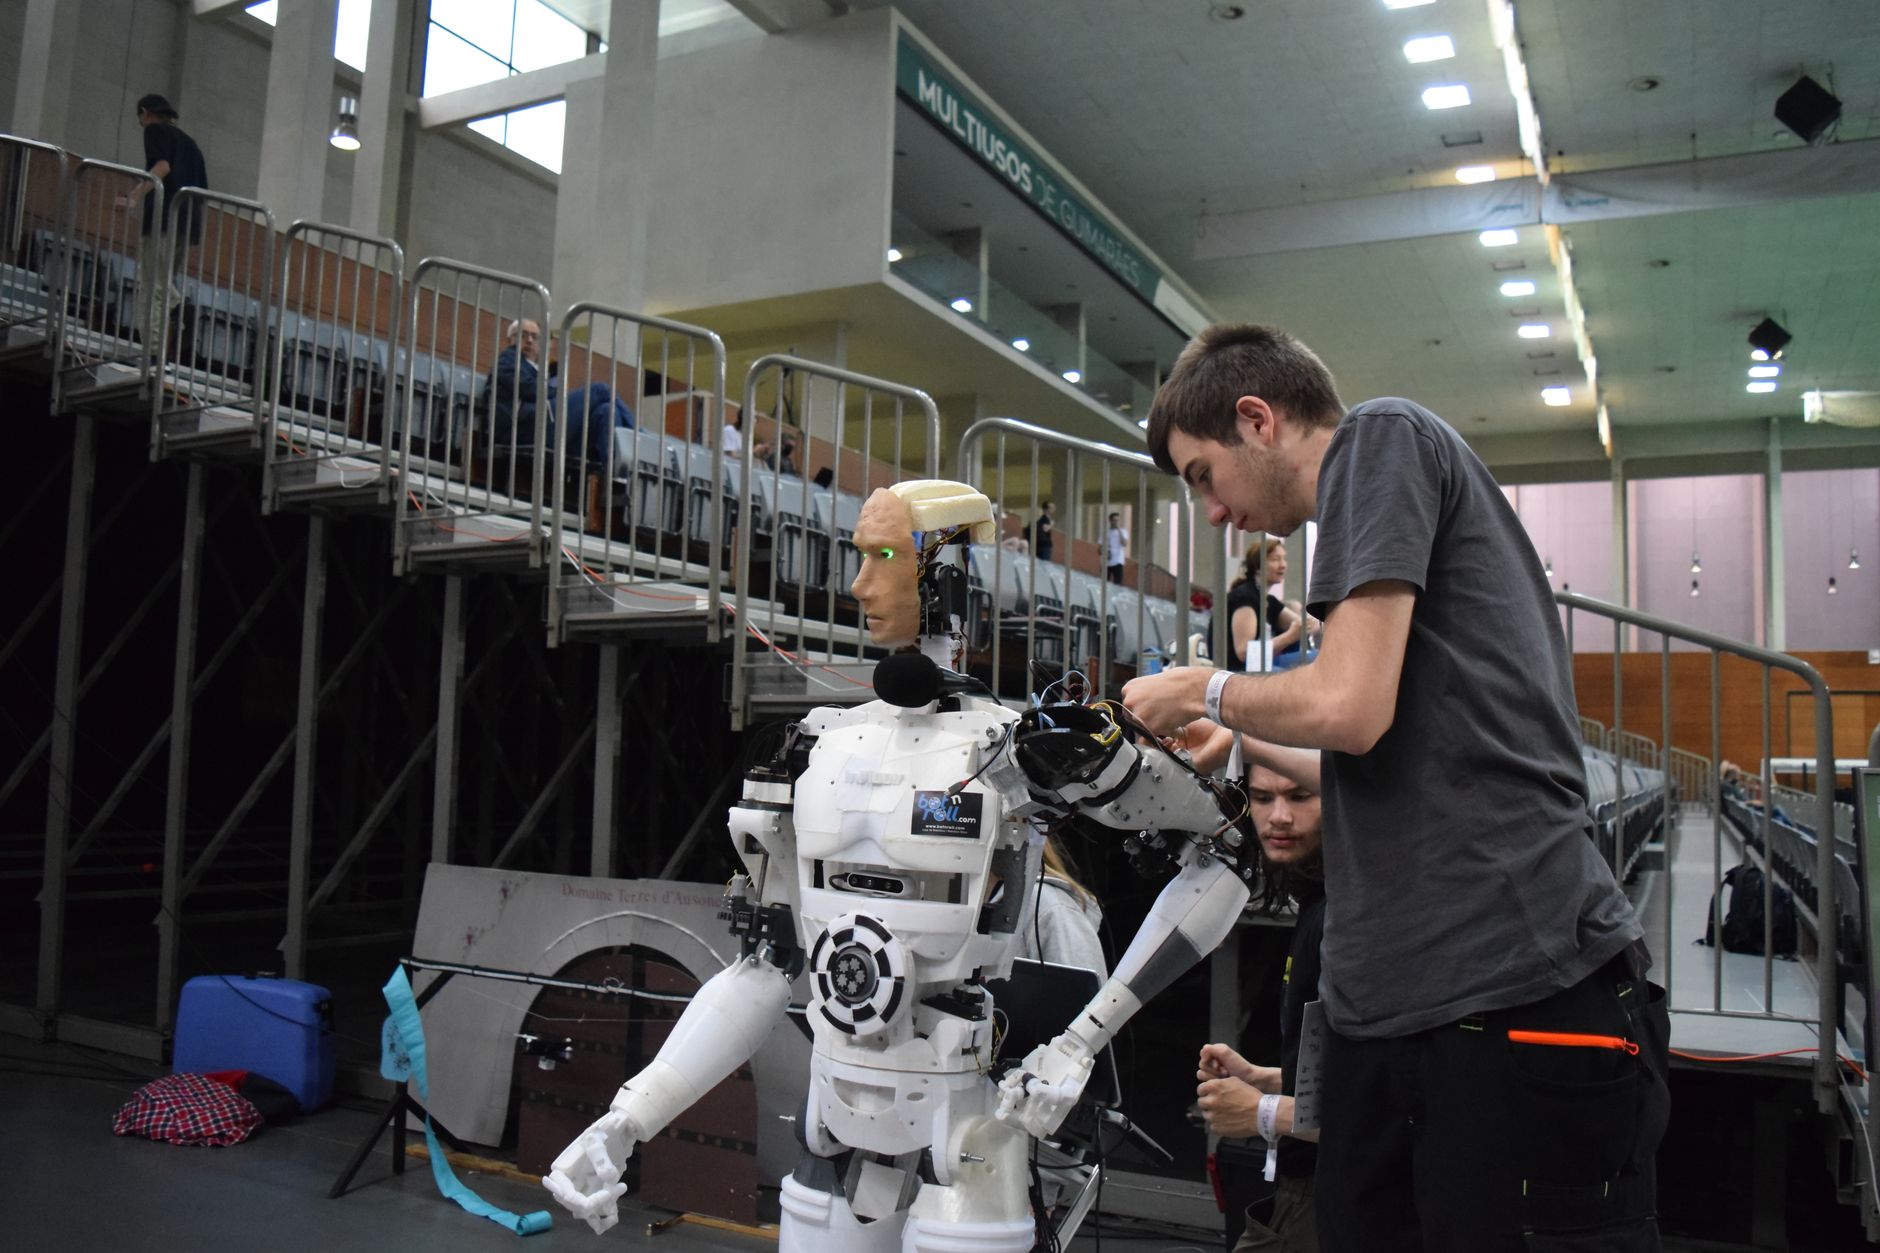
Living tissue and synthetic engineering are converging in a robotics laboratory at ETH Zurich, where researchers have successfully engineered biohybrid muscle actuators capable of flexing with visible force. Led by Professor Robert Katzschmann at the Soft Robotics Lab, the project utilizes laboratory-grown mouse muscle cells attached to artificial skeletal scaffolds. These centimeter-scale actuators represent a tenfold performance leap over previous experimental iterations, enabling small machines to perform dynamic physical tasks such as swimming, jumping, walking, and grasping.
The breakthrough relies less on sheer muscle volume and more on how biological tissue integrates with man-made structures. By employing a digital design process built entirely from scratch, the team abandoned rigid geometric constraints in favor of a specialized scaffolding system featuring tiny grooves. These grooves allow the living tissue to securely anchor itself and pull against the artificial frame, transforming microscopic twitches into macro-scale movements visible to the naked eye.
While these biological machines currently require a specialized nutrient solution to keep the muscle cells alive and functioning, the long-term horizons extend far beyond laboratory glassware. Far from building science-fiction cyborg armies, the researchers emphasize that these biohybrid systems offer profound practical implications for future medical devices and specialized exploration tasks. As engineers continue refining how living cells cooperate with electronics, the boundary between biology and machine engineering continues to blur.
ETH Zurich Researchers Build Biohybrid Robots Powered by Living Muscle Tissue


Comments